If a machine could take care of all its own maintenance, I would like it to start with my house. Nothing particularly ambitious. Clean the filter, notice the strange noise before it becomes an expensive noise, and stop waiting until I’m busy to announce that something needs attention.
Russia has a considerably larger version of that wish: an orbital station equipped with robots that could help keep it working when a crew isn’t there. The vision is appealing. A mechanical arm tends equipment above the curve of Earth while the people who built it stay safely inside, or down on the ground.
But “self-maintaining space station” is a phrase that needs a little unpacking before we let it float away with the imagination. It doesn’t mean a station grows new parts, repairs every possible failure, or becomes independent of the people paying for it. It describes an ambition to move more servicing work into robotic systems and automation.
That ambition is interesting enough. Maintaining a place where people can survive in orbit is an enormous amount of work. If machines can handle more of the repetitive, delicate, or dangerous jobs, that changes what a crew can spend its time doing.
The story also changed after this article was first published. Russia’s proposed station has gone through revisions involving its orbit, its relationship to the International Space Station, and its deployment schedule. So let’s separate the announcement, the engineering, and the parts we still haven’t seen demonstrated. I’d rather understand the actual machine than give a very confident tour of one that exists mostly in a headline.
What Russia actually announced
In June 2025, First Deputy Prime Minister Denis Manturov described a planned Russian station as a robotic platform able to service itself, referring to a patented solution. The Russian government’s public information site reported the statement and the ambition to use experience from the technology in a future lunar program.
That was an announcement about a proposed capability. It wasn’t a report that a fully functioning self-maintaining station had already been built, launched, and left alone to get on with its evening.
The broader project is usually called the Russian Orbital Station, or ROS. Earlier material often uses ROSS, for Russian Orbital Service Station. Unfortunately, ROS is also used for the Russian Orbital Segment of the existing ISS, which is the sort of naming decision that makes research tabs multiply like zucchini in August.
The context tells you which one a source means. A description of equipment currently attached to the ISS may concern the existing segment. A presentation about a future independent outpost concerns the proposed station. Mixing them can make a planned system sound as if it has already accumulated years of operational experience.
The word “patented” needs the same care. A patent documents an invention and a legal claim to protection. It doesn’t certify that an entire station has passed flight tests or that every feature mentioned in a political announcement is ready to use.
I couldn’t verify a single patent supporting every capability described in the earlier version of this article. Rather than attach a convenient patent number to a much larger claim, I’m keeping the announcement and the independently identifiable technical documents separate.
The plan has moved since the polar-orbit headlines
Earlier descriptions put the future station in a near-polar orbit. That would provide a different pattern of Earth coverage from the ISS, including access to high latitudes. It was a major part of how the project was presented.
By April 2026, the publicly described architecture had shifted toward using resources from the ISS during assembly and then separating a new cluster. Chief designer Vladimir Kozhevnikov described a sequence involving a new node, science-and-power module, airlock, and Nauka, with independent operations targeted around 2030 and a fuller configuration by 2034.
Those dates describe a plan, not a completed deployment. References to 2028 concern early assembly steps; they shouldn’t be presented as proof that a fully independent station will be operating then. An ISS-based start also changes the orbit discussion. You can’t treat the earlier polar proposal and the later ISS-linked architecture as the same settled design.
That’s the current distinction I want readers to keep: an evolving station proposal, with robotic servicing ambitions, rather than a finished spacecraft following an immutable timetable. The hardware has to be built, integrated, launched, and tested before any of those ambitions become routine operations.
Why an orbital station needs so much attention
A station is a building, a vehicle, a laboratory, and a life-support system sharing an unusually unforgiving address. On Earth, a broken pump can be inconvenient. In orbit, which pump broke and what it supports can determine how much time you have to respond.
Power has to be generated and stored. Equipment has to remain within workable temperatures. Computers have to communicate. Docking interfaces have to function. When people are aboard, the atmosphere, water, and waste systems become part of the same tightly managed arrangement.
The outside is exposed to vacuum, radiation, debris impacts, and materials degradation. The inside contains all the ordinary trouble that comes with people and machinery sharing a small enclosed space. Filters still need attention. Things still wear out. The view doesn’t excuse anyone from housekeeping.
NASA’s space-environment guidance describes hazards including atomic oxygen, which can erode vulnerable materials in low Earth orbit, and contamination from substances released by spacecraft materials. Space isn’t simply an empty background that leaves your equipment politely alone.
This is why the maintenance conversation matters. We tend to celebrate launch day, docking day, the beautiful photograph through the window. Between those moments sits the sustained labor of keeping everything functional. A station that survives for years needs a maintenance strategy every bit as real as its launch strategy.
A robotic arm doesn’t need a spacesuit
The most understandable part of this idea is a mechanical arm handling equipment outside. It can move a camera into position, carry a payload, or work with a component designed to be removed and replaced. It doesn’t need oxygen, a pressure garment, or a carefully scheduled return through an airlock.
That doesn’t make the task effortless. The arm has to reach the worksite without hitting something important. Its tool has to engage the right fitting. Cameras and sensors have to provide enough information to distinguish “correctly attached” from “looks attached if you squint.”
A robot also needs a stable relationship with the station. One end may attach to a designated base point while the other manipulates equipment. The structure and control system must accommodate the loads and movement involved. Floating doesn’t remove mass or inertia.
If you’ve ever tried to loosen a stubborn lid while the container slides around the counter, you already understand a tiny piece of this problem. Applying force to one thing affects something else. Now remove the counter, put expensive hardware nearby, and make the whole arrangement orbit Earth.
The gripper is only the visible tip of a much larger system. Power, software, mounting points, tools, lighting, communications, and replacement hardware all have to cooperate. A beautifully articulated arm attached to inaccessible equipment is still going to have a frustrating afternoon.
We already have robots doing maintenance in orbit
This is where the earlier article needed a significant correction. Robotic station maintenance didn’t begin with the Russian proposal. The ISS already has a long history of robotic systems moving equipment and supporting servicing work.
Canada’s Dextre can replace certain exterior equipment and electrical components. It works with Canadarm2 and the Mobile Base System, with ground teams operating the robots. That is real maintenance performed in space, even though the people directing it are somewhere with chairs and gravity.
In 2014, the Canadian Space Agency even described planned camera replacements within its station robotics system as robotic self-repair. That history makes an unqualified claim that a future Russian station will be the first machine to tend itself misleading. The exact novelty would need to be defined and demonstrated.
The European Robotic Arm adds another useful comparison. ESA describes it as able to perform automatic or semi-automatic tasks, use preprogrammed sequences, and accept control from operators. It can move between designated attachment points on the Russian segment.
These systems don’t make future ambitions uninteresting. They give us a sensible starting point for evaluating them. The question becomes what additional tasks, autonomy, reliability, or coverage a new design could provide beyond what already exists.
Remote control and autonomy are different things
An empty worksite doesn’t necessarily mean an independent machine. A robot can perform a task while being controlled from Earth. It can execute a preplanned sequence. It can adjust some details locally. Or it can have authority to diagnose a problem and select a response within defined limits.
Those are different levels of responsibility. An article that describes all of them as “the station thinking for itself” hides the most important engineering questions.
For a hypothetical camera replacement, operators might identify the problem, choose the spare, check the robot’s path, approve the operation, and monitor its progress. Software might control the detailed joint movements. The arm does the physical work, but the decision-making is distributed across equipment and people.
A more autonomous arrangement might detect an abnormal condition, compare readings, and enter a safe state without waiting for a command. That can be valuable even if it never attempts a repair. Sometimes the smartest available action is to stop moving and avoid turning one problem into three.
I appreciate this kind of restraint. We often imagine a clever machine proving itself by doing something dramatic. In a crowded spacecraft, proving that it knows when to pause may be considerably more useful. “I decided to improvise” is charming from a musician. From a robotic arm beside a radiator, I’d like considerably more detail.
Maintenance starts with making things replaceable
The least glamorous feature may be the most important: equipment has to be designed so a robot can service it. That means access, clear interfaces, appropriate attachment points, and a way to confirm that the replacement is secure and working.
Think about the difference between changing a battery through a little compartment and disassembling a device held together with glue. Both devices contain batteries. Only one was designed to make replacement pleasant.
In orbit, the consequences are larger. A standardized unit can give the robot something predictable to grasp. Captive fasteners can help prevent small pieces from escaping. Connectors can be arranged so the task doesn’t depend on a flexible wrist reaching behind an obstruction.
These are general design principles, not a claim that every proposed ROS component already includes them. They explain why “add a robot” is an incomplete maintenance strategy. The station and the servicing equipment need to be designed together.
There’s a lovely practical idea here: plan for the moment something fails while you still have the freedom to make that failure manageable. It’s the engineering equivalent of putting a zipper somewhere you can actually reach it. You only appreciate the thoughtfulness later, when you need it.
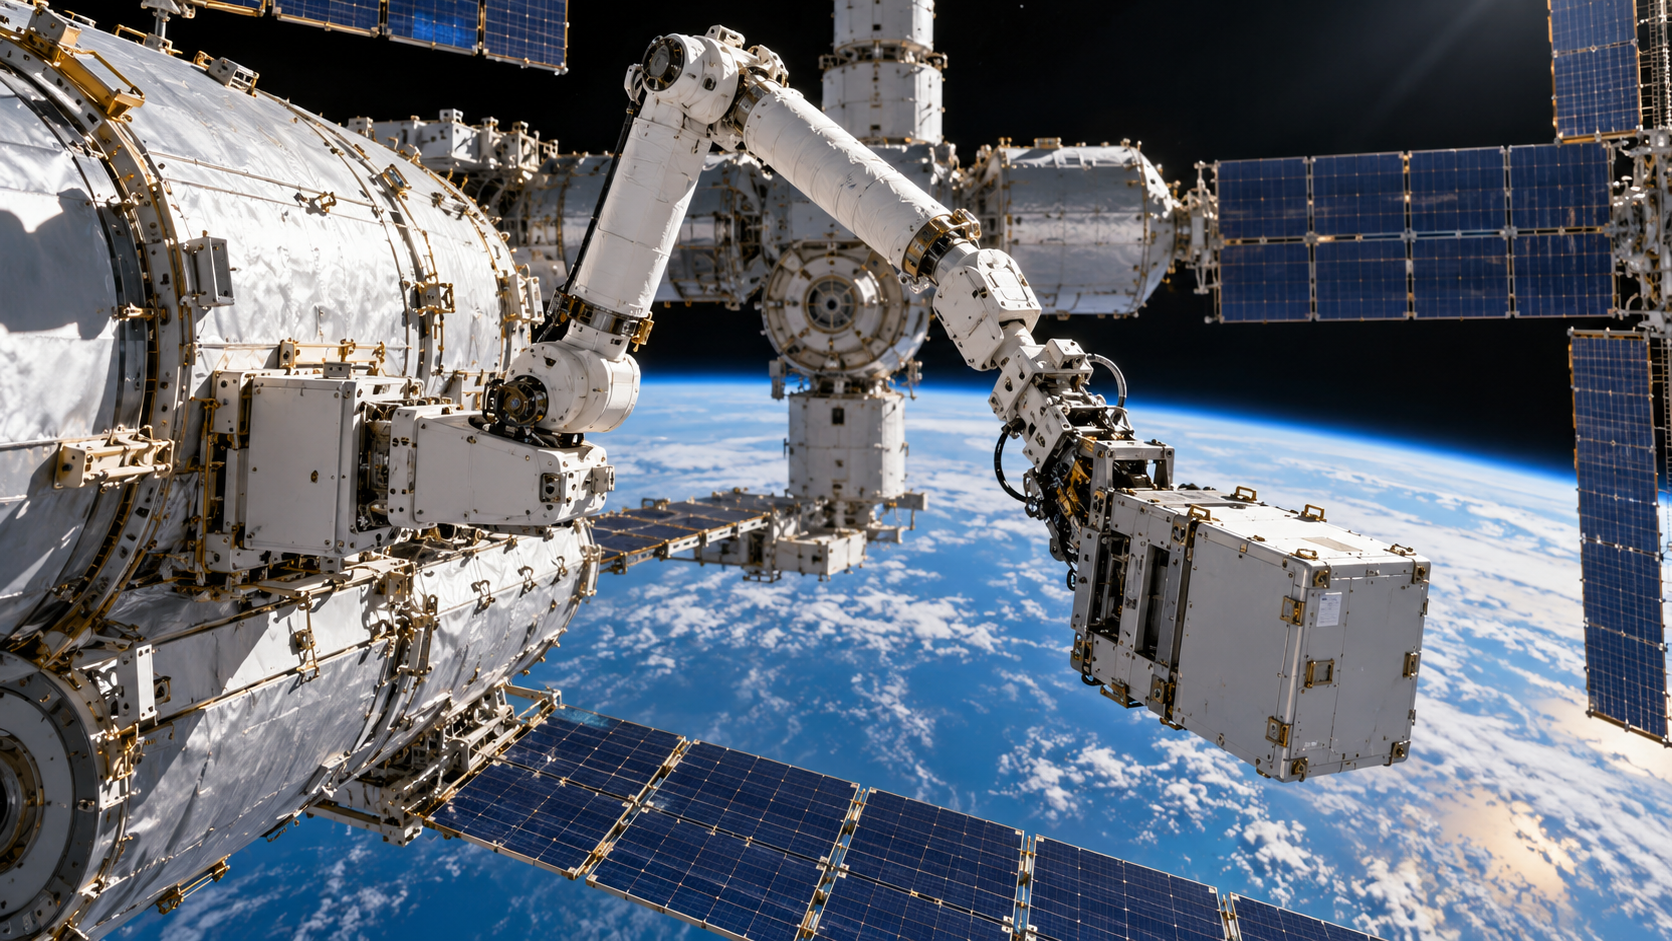
AI-generated concept illustration above, not an official ROS design or a photograph of an operating station.
A digital twin is useful, but it isn’t a crystal ball
One identifiable Russian patent, RU2837711C1, describes a method for manufacturing or servicing spacecraft in orbit using standardized modules and digital twins. Its text discusses ground and onboard facilities exchanging information, testing components, and updating the model with results.
It also describes possible use of a robotic manipulator associated with Nauka or a future Russian station. That makes it relevant to the servicing conversation. It doesn’t establish that this is the specific patent behind every statement in the 2025 announcement, or that the proposed system has flown.
A digital twin is a model linked to information about the actual hardware. In a servicing context, it can help compare expected behavior with measured behavior and support planning or tests. Its usefulness depends on how accurately it represents the real system.
Imagine a carefully maintained record of a garden: the layout, what was planted, changes to the watering system, and observations as the plants grow. That record can help you identify what changed when one bed starts struggling. It can’t replace looking at the plant, and it becomes less useful if nobody records that a hose was moved.
The spacecraft version is far more technical, but the same general limitation applies. A model can be wrong, incomplete, or out of date. Good engineering includes checking the model against reality rather than assuming the computer’s tidy picture must be the truth.
What happens when the maintenance robot needs maintenance?
This is the question I always want to ask. Giving the station a mechanical caretaker adds machinery that can develop problems of its own. Motors, joints, cameras, connectors, and computers don’t become immortal because they’ve been assigned a helpful job.
A sensible design has to consider recovery. Can the arm release a tool safely? Can it stop in a position that leaves an important access route clear? Can another system inspect it? Does a failure leave the station worse off than it would have been without the attempted repair?
Those are questions to ask of any proposed system, not confirmed specifications of ROS. They explain why a good demonstration needs to include more than a successful movement in ideal conditions. The recovery plan is part of the capability.
We understand this perfectly well on Earth. A backup key is useful until it’s locked inside the same house. A spare pump is useful until you discover it needs a connector you don’t have. Redundancy requires thought about how failures interact, not simply buying two of everything and feeling reassured.
For an orbital station, that thought has to happen long before the failure. You don’t want the first discussion about a stuck component to begin when it is already stuck outside, blocking the only robot that can reach it.
Self-maintaining doesn’t mean self-supplying
Even a highly capable robotic system needs something to install. A replacement camera doesn’t appear because software has correctly identified that the old one has failed. Spare hardware has to be manufactured, tested, transported, stored, and kept in usable condition.
The station also needs energy for its operations. Servicing tasks compete with other demands. A robot handling a problem during a power shortage is operating under different constraints from a robot performing scheduled work with plenty of capacity available.
This is why I’d avoid “self-sustaining” as a casual synonym. It suggests a much broader independence than robotic maintenance provides. A station can operate without a crew for a period and still depend heavily on Earth for supplies, commands, expertise, and money.
There’s nothing disappointing about that. The ISS itself demonstrates how much infrastructure exists behind a place that appears to float so gracefully in photographs. The station is the visible end of an enormous support system.
I think of it like a beautiful dinner arriving at a table. You see the plate. You don’t see every delivery, prep task, equipment repair, and person who made the evening possible. Spaceflight has its own version of the kitchen, and the kitchen does not disappear when the robot gets better.
An orbital workshop is different from a rocket launchpad
The original article also imagined spacecraft launching from the station as if the station were a little spaceport sending missions everywhere. Orbital deployment and servicing can be valuable capabilities, but they need a clearer description.
A small satellite released from a station begins with a velocity and orbit close to the station’s own. Releasing it safely requires planning so the two objects separate rather than become a collision problem. Going somewhere substantially different requires an appropriate change in velocity and the equipment to provide it.
A probe doesn’t become Moon-bound merely because a robotic arm lets go. The station’s altitude, orbital plane, spacecraft propulsion, mission design, and safety constraints all matter. The arm handles a payload; it doesn’t cancel orbital mechanics.
There is still an interesting possibility in treating orbit as a place to assemble, inspect, or service equipment. A workshop could support tasks that would otherwise require a separate vehicle or a replacement launch. But each proposed job needs its own technical and economic case.
I’m happy to imagine the possibilities. I just want to distinguish a plausible research direction from a feature that has already been installed, tested, and put on the schedule for Tuesday.
The cold, the heat, and the misleading silence
Space looks still in a photograph. The equipment is dealing with changing illumination, internal heat, and the need to reject that heat through radiators. There’s no surrounding atmosphere to carry heat away by ordinary outdoor convection.
That doesn’t mean every component instantly swings through the same enormous temperature range whenever the station crosses into shadow. Insulation, thermal mass, heaters, coolant loops, coatings, and orientation all affect what a particular piece of hardware experiences. The design exists to keep important temperatures within limits.
The earlier article described the hiss of hydraulics out in space. A dramatic soundtrack, but sound doesn’t travel through vacuum the way it travels through air. Vibrations can move through the structure, and astronauts inside may hear machinery through the cabin environment. An outside observer wouldn’t hear a cinematic mechanical whisper drifting across empty space.
There can also be orbital night. Passing into Earth’s shadow is a real lighting and power condition, even if the cycle is different from the long nights we experience on the ground. Whether and how long a spacecraft is eclipsed depends on its orbit and the geometry with the Sun.
I love a beautiful space image. I also love the less romantic detail underneath it: while Earth glows blue in the background, somebody has to make sure a motor stays warm enough to work. The spectacular view and the practical problem occupy the same photograph.
What would make the proposal convincing?
I’d look for demonstrated tasks and clearly stated limits. Which components can be serviced? Who diagnoses the fault? Who authorizes action? What happens if a camera loses its view or the fitting doesn’t move as expected?
I’d also want to know how a successful repair is verified. Moving a box into place is one step. Showing that it is securely attached, correctly connected, and functioning without causing another problem is the part that makes it maintenance.
NASA’s Robotic Refueling Mission provides a useful example of breaking ambitious goals into specific demonstrations. It used tools and task boards to test operations such as cutting protective material, handling caps and valves, and transferring fluid. Those tests were performed through ground-controlled robotics, with substantial preparation.
That kind of detail gives an achievement meaning. It helps us see exactly what was attempted, what worked, and what remains to be done. A broad promise can be inspiring. A well-defined test is something we can learn from.
For ROS, there is still distance between the announced vision and a station routinely completing its own servicing tasks. I’m interested in watching that distance shrink through evidence, rather than closing it with confident verbs.
The part I’d actually celebrate
I’m apparantly very susceptible to the image of a robot working above Earth while everyone sleeps. There is something wonderful about building a machine that can take on a dangerous job and leave people with more time for the work they went into space to do.
But I don’t need to imagine the station developing patience, a personality, or the ability to survive without support. I’d be impressed by a camera replaced correctly, a small problem found early, or a maintenance task completed without someone having to put on a spacesuit.
Those achievements are practical and specific. They can also be beautiful. Care doesn’t stop being care because it involves an electrical connector instead of a grand gesture.
Russia’s proposed orbital station may eventually demonstrate a useful next step in that direction. For now, it is an evolving project with ambitious servicing plans, building on a field where international teams have already done remarkable work.
I’d still like my household appliances to learn to warn me before an expensive noise becomes an emergency. But if the orbital version gets there first, I’ll happily admire the view while reading the maintenance report. Someone, somewhere, will still have had to make sure the spare part was in the right drawer.
A compact household tool kit would cover a useful piece of my own maintenance ambitions. Give me the right screwdriver, a labeled place to put it back and a chance of finding it again when something starts rattling.
Related Reads You Might Enjoy
The Black Hole Explorer Mission: Listening to the Silence That Shapes the Universe
Three Months to Mars: How Starship Is Rewriting the Clock on Interplanetary Travel
The Floating Magnet That Shouldn’t Exist: Why This Levitation Experiment Is Rattling Physics
The Exoskeleton That Listens to the Brain: Japan’s HAL Suit and the Future of Movement
The Plant That Eats Metal: How Rinorea niccolifera Could Clean the Earth
The Light That Shouldn’t Exist: Discovering Stars in the Darkest Corners
The Internetless Revolution: Jack Dorsey’s New Chat App and the Rise of Offline Resistance
Will Nanorobots Make Us Immortal by 2030? The Future of Forever
The Sound of Extinction: How Disappearing Animals Take Silence With Them
The Building That Breathes: How Moss Bricks Are Changing the Future of Architecture
The Mushroom That Can Eat Plastic, and Might Save the World
Cosmic Alchemy: How Magnetar Flares Scatter Gold Across the Universe
Sources and further reading
Updated October 2026.
Russian government information: June 2025 announcement
Chief designer’s April 2026 architecture and schedule, reported by Interfax
Russian servicing patent RU2837711C1
Canadian Space Agency: About Dextre
Canadian Space Agency: 2014 robotic self-repair announcement