Gillbert the Robot Fish: Collecting Plastic, One Gulp at a Time
Updated October 19, 2026. Gillbert is a battery-powered prototype that collects particles for sampling. It doesn’t digest plastic or use pollution as fuel.
A robot fish with a mouth full of plastic is a very effective way to get my attention. Give it the name Gillbert and I’m already emotionally invested, which probably says something about my standards for science news. The real project is interesting enough to deserve a proper explanation, especially because the version circulating online has acquired an extraordinary digestive system that the researchers never built.
Gillbert filters particles from water. Collecting those particles could help researchers understand where pollution is going, and that’s a useful ambition with plenty of engineering behind it. The claim that the fish consumes plastic to keep itself alive belongs to the exaggerated version of the story. My earlier headline repeated that promise, so I’ve changed it and brought the explanation back to what the documented prototype actually does.
I still find something delightful about the idea of borrowing a fish’s shape to investigate what we’ve put into its environment. I just want the delight to survive a trip through the source material, preferably without requiring us to invent a metabolism along the way.
A student’s sketch became a working prototype
The University of Surrey announced the project in October 2022 after Eleanor Mackintosh’s design won the Natural Robotics Contest. The competition invited ideas for robots inspired by nature, with the winning concept developed into a working machine. Robert Siddall led the contest, and the result was a salmon-sized robotic fish with filtering gills. Surrey also made the design available openly, giving the project an educational life beyond the original demonstration.
I like that the starting point was an observation someone could make without owning a robotics laboratory: fish move through water, and structures around their mouths and gills interact with what passes through. Turning that observation into hardware takes engineering, but the question itself is approachable. A good science story can begin with someone wondering whether a familiar shape might do a different job.
That’s also why the original date matters. This is a project introduced in 2022, with a research paper published in 2023, rather than proof that a new commercial fleet has just begun cleaning the oceans. Keeping the timeline visible lets us appreciate the prototype for the stage of development it represents.
What Gillbert actually does
The technical paper describes a remotely controlled fish powered by a battery, with motor-driven swimming and mesh-lined gills. Water enters the head cavity, and particles can be retained as water passes through the filtering structure. The design uses a two-millimeter nylon mesh. In the reported lake tests, the robot demonstrated surface swimming and steering; the authors also described limitations and future improvements.
The same paper makes a particularly important point: widespread ocean filtration would struggle to distinguish plastic from valuable organic particles and could harm aquatic life. The researchers identified sampling and better pollution data as a more useful role. Their proposed docking station would help unload and analyze samples, clean the robot, and recharge it; those were future plans in the paper, rather than completed capabilities.
That account gives us a machine with a defined job and an engineering path to explore. I think there’s room to enjoy that without calling it a self-sufficient creature. A rechargeable research tool can be impressive, even if somebody still has to remember where they left its charging cable.
A filter has a size limit
NOAA defines microplastics as plastic pieces or fibers smaller than five millimeters. They include fragments, pellets, foam, film, and fibers, with sources ranging from larger items breaking apart to material shed during ordinary use. That category covers a wide range of sizes, including pieces you can see and particles far smaller than a visible speck.
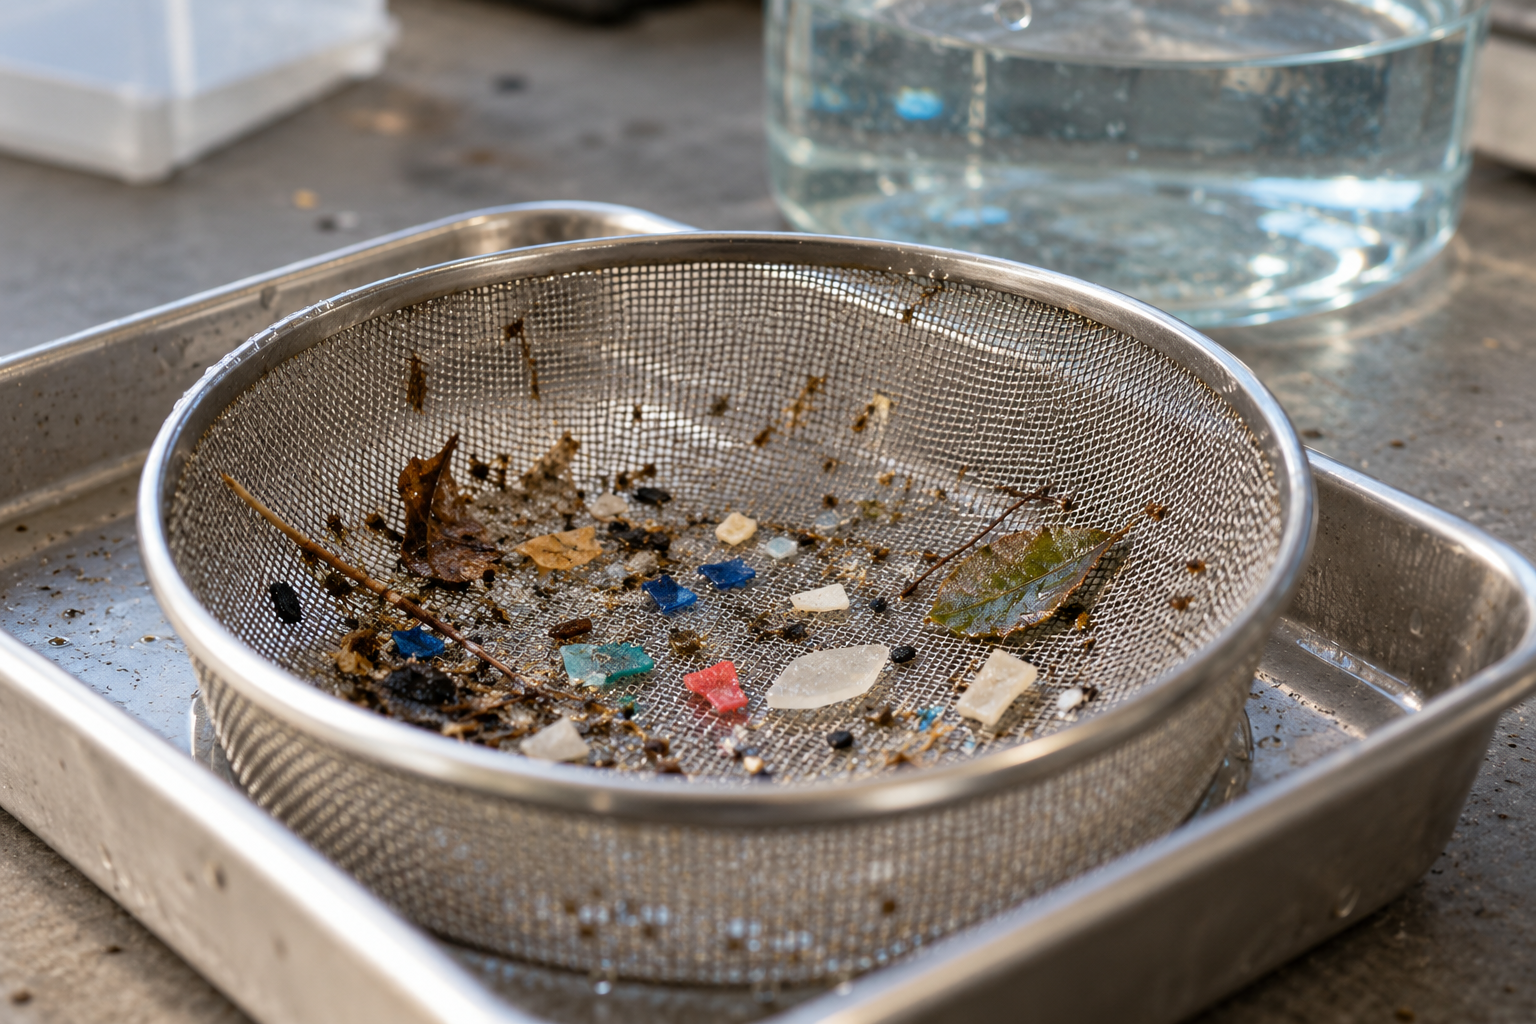
The two-millimeter mesh described for Gillbert therefore needs to be understood within that range. A filter opening has a physical size; saying that a device collects microplastics doesn’t mean it captures every particle that falls under the definition. It certainly doesn’t establish nanoplastic removal. Shape, orientation, and the way water moves through a filter also matter when asking what remains in a sample.
I find the scale easy to lose in a headline, because “micro” sounds like a promise of invisibility. A few visible colored fragments can belong to the same broad pollution category as material requiring laboratory analysis. If we want to know what a collection device achieves, the useful question is which size range it targets, followed by how that performance was measured.
The material in the filter still needs an explanation
A basket of particles gives a researcher material to investigate, but identifying that material is another step. An especially useful example comes from NOAA’s February 2026 account of microplastic sampling around Monterey Bay. Researchers collected beach and ocean-water samples using different sieve sizes, then used visual examination, microscopes, and infrared spectroscopy for different portions of the material. The work shows why collection and identification belong in the same conversation.
That’s a separate project, rather than a Gillbert deployment, and it helps explain what a sample can be for. A bit of material caught in a mesh doesn’t come with its source and chemical identity politely printed on it. The laboratory work helps establish what was collected and which questions the sample can answer.
For a robot, I’d want the sampling location, depth, time, and collection method recorded alongside the contents. That’s my description of useful evidence, rather than a claim that Gillbert already produces a complete monitoring record. If a future tool makes a sample easier to collect while preserving the information needed to interpret it, that could be a meaningful contribution.
Sampling and cleanup answer different questions
Cleanup asks how much unwanted material a system removes and what happens to it afterward. Sampling asks what’s present in a particular place under particular collection conditions. The activities can overlap, but their success measures differ. A small sample can be scientifically valuable even when its contribution to the total amount of pollution removed is modest.
NOAA’s explanation of garbage patches helps put that distinction in perspective. The debris is spread through moving water, with small particles mixed from the surface into deeper areas, rather than arranged as a solid island waiting for a giant vacuum. That distribution makes broad removal difficult, while larger debris and accessible coastal locations present different collection opportunities.
I’m interested in tools that help us choose where effort belongs. If measurements reveal a source worth addressing or show whether an intervention is working, the information could matter well beyond the amount caught in one container. That’s a possible use for better data, rather than a result I’m assigning to this particular prototype. Gillbert can have an interesting future without being asked to personally tidy an ocean before lunch.
The pollution-powered robot is a different project
There is genuine research on robots that obtain energy from their surroundings. Bristol’s Row-bot, described by the university in 2015, used a microbial fuel cell supplied with nutrient-rich water. Microbes break down suitable organic matter, and the system uses the resulting electrical energy. The project explored whether that energy could support the robot’s feeding and movement under the tested conditions.
That’s a different mechanism from trapping plastic in a mesh. A fuel source that supports microbial metabolism has to be chemically usable by that system; a collected fragment doesn’t become available electricity just because both activities involve dirty water. Putting Row-bot’s energy system into Gillbert’s story would combine two separate research projects and invent the missing engineering between them.
I understand the appeal of the combined version. Pollution powers cleanup, the machine keeps going, and a messy problem acquires a satisfyingly circular ending. It’s the sort of story that practically writes its own cheerful caption. The actual work is more specific, which gives us a much better place to ask what could be developed next.
Even an edible robot tells a different story
Another project reported by EPFL in 2025 approached the environmental footprint of small aquatic robots from a different direction. Researchers made boat-shaped devices using fish-food material and biodegradable components. Released fuel changed surface tension to propel them across the water. Future environmental sensing was among the possibilities discussed; these devices weren’t Gillbert, and they weren’t converting collected plastic into fuel.
I bring that up because words such as fish, food, fuel, and robot can travel between headlines until several distinct experiments start looking like one miraculous animal. A device made to be edible, a machine powered by organic nutrients, and a fish-shaped sampling robot each asks a different engineering question. Their differences are part of what makes the field interesting.
It also puts a useful question back on the table: what happens to the robot itself? A machine intended for environmental work has materials, a power supply, maintenance needs, and a possibility of being lost or damaged. Those considerations belong in any assessment of benefit, alongside the job the machine is designed to perform.
What I would want to see next
Before getting excited about fleets, I’d want a clear account of reliability over repeated outings, the particles retained, and what else enters the collection chamber. I’d also want to know how often filters need attention, how samples are retrieved, and what the whole operation costs in energy and maintenance. These are questions I’d use to evaluate future claims, rather than results the existing project has already demonstrated.
Wildlife interactions would deserve their own evidence. A fish-shaped body doesn’t automatically establish that a device is harmless, and a filter’s attractive purpose can’t tell us what happens to small organisms in its path. Careful testing would help determine appropriate locations and operating conditions. The goal is a useful tool that fits a particular task, with its tradeoffs measured honestly.
I’d also want comparisons with a simpler collection method. If a person can safely take the same sample using less equipment, the robot needs to explain what it adds, perhaps access to a difficult spot or more consistent collection. That comparison would help identify where a fish-shaped device earns its place. I like the invention, but I’d still ask it to explain why this particular task benefits from having a tail.
I’d be happy to read about a small improvement that held up in field trials. Better sample retrieval or fewer failures might be less dramatic than a swarm circling the planet, but those are the kinds of changes that make an invention easier to use. Engineering progress often has the deeply unglamorous personality of a seal that finally stops leaking, and I respect that.
Prevention still has a job
The United Nations Environment Programme’s 2023 Turning off the Tap report describes a broader approach to plastic pollution. It emphasizes reducing problematic and unnecessary plastic use, redesigning products and packaging, expanding reuse, improving recycling, and dealing with existing waste. That framework makes room for cleanup while also addressing how material enters the environment in the first place.
For me, that’s the context in which a robot becomes most interesting. A sampling tool could sit alongside better waste collection, product changes, and efforts to prevent leakage, with each part judged on what it contributes. I don’t want an appealing machine to become permission to stop asking where the waste came from. The beginning of the story matters as much as the retrieval at the end.
For a small ocean-themed reminder, you can look at the 4ocean bracelet. I’d check the current product details and cleanup commitment before buying; the listing’s claims belong to that product and shouldn’t be confused with evidence about robotic filtration. A bracelet can be something you enjoy wearing while the larger work continues elsewhere.
A fish-shaped reason to keep asking questions
I’m definately susceptible to an invention with a good name, especially when it combines an unfamiliar mechanism with an animal everybody recognizes. Gillbert gives me a reason to read about filtering gills, sampling methods, and the very different ways researchers are approaching pollution. I value that trail of curiosity, even after the impossible digestive system has been removed from the story.
What stays with me is the movement from an approachable idea to something that can be built, tested, and improved. There’s room for imagination at the beginning and honest measurements afterward, with neither required to do the other’s job. I’d like to see more of that kind of invention: specific about its purpose, open about its limits, and interesting enough that someone else starts asking a better question.
Related Reads You Might Enjoy
The Rain Has Changed: The Quiet Poison of TFA and the Birth of a New Acid Sky
The Sound of Trees Crying: What Plants Really Do When They’re Stressed
Blood Plastic: The Audacious Claim to Filter Microplastics from Our Veins
The Plant That Eats Metal: How Rinorea niccolifera Could Clean the Earth
Why the Tuna You’re Eating Might Be Closer to Extinct Than You Think
This Common Ingredient Tricks Your Brain and Could Be Fueling Your Cravings
The Wine Climate Crisis: Is Terroir Shifting Beneath Our Feet?
How the Brain Reacts to Light Pollution: What Happens When We Forget the Night
Unexplained Bird Deaths in California: The Sky Is Falling, and No One Knows Why
Sources and further reading
University of Surrey (2022), Robotics researchers turn the public’s ideas into robo-fish reality
Siddall et al. (2023), The Natural Robotics Contest: crowdsourced biomimetic design
Author manuscript of the Gillbert research paper, including prototype details
NOAA (2026), Following microplastics from shore to sanctuary
University of Bristol (2015), A Row-bot that loves dirty water
EPFL (2025), Eco-friendly aquatic robot is made from fish food
The generic robot, filter, and shoreline images are AI-generated editorial illustrations. They do not show the actual Gillbert prototype, a measured sample, or a documented research site.